Omkar Sudhir Patil
About Me
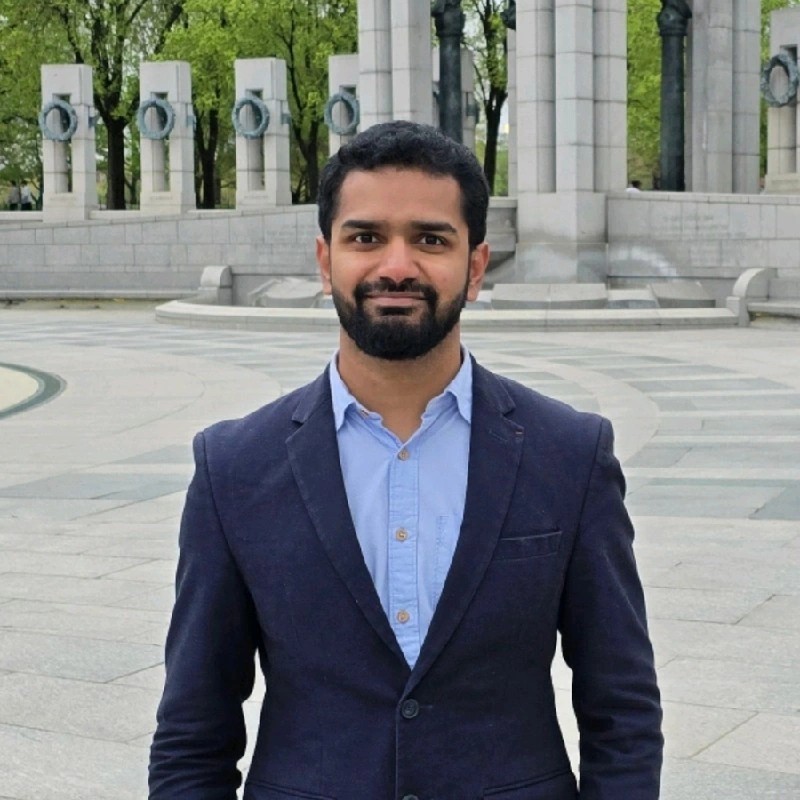
I am a tenure-track Assistant Professor in the Department of Electrical and Computer Engineering at Louisiana State University, where I lead the Adaptive Control and Robotics (ARC) Lab. My research integrates control theory, adaptive methods, and deep learning to build autonomous systems with mathematically certifiable stability and safety guarantees.
My work has focused on Lyapunov-based learning and control for uncertain nonlinear systems, including deep neural network adaptation, safe control with barrier methods, and online physics-aware learning. I aim to develop methods that can move reliably from proof to platform, with validation on real robotic systems.
ARC Lab at LSU
Adaptive Control and Robotics Lab
ARC Lab works on the frontier between modern AI and nonlinear control: systems that can learn online in uncertain, real-world environments while preserving provable stability and safety through Lyapunov-based certification.
Funded PhD positions are open for Spring 2027 and Fall 2027. I am especially excited to connect with students interested in adaptive control, safe autonomy, multi-agent systems, physics-aware learning, and learning-enabled robotics.
Interactive Demos
Quick Tools and Accessories
Tools I made for my personal use but do not mind sharing with everyone.